API Demo

Finalist — Google Gemma Hardware Hackathon 2026, hosted by AGI House

Built a Gemma 4–powered Unitree robot driven by a Google Pixel phone. We deployed NVIDIA SONIC whole-body motion control on the robot and wired it to the model's decisions: the phone's camera captures the 3D scene, Gemma understands the scene and generates action commands, and SONIC executes them as coordinated movement — the robot walks forward and high-five a person sitting at a distance. Physical engagement, end to end.
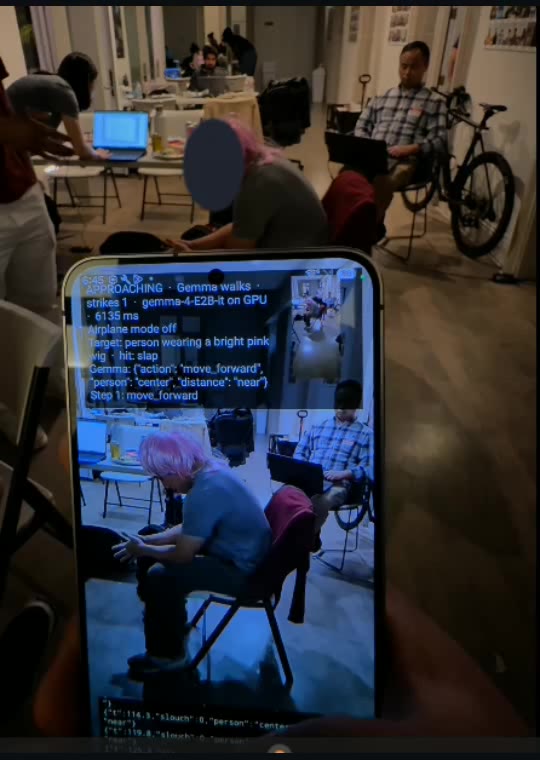
Finalist — Google Gemma Hardware Hackathon 2026, hosted by AGI House

Compact VLM Classification & Reasoning with Reinforecment Learning

Large vision-language models can be computationally expensive to deploy, particularly for specialized visual understanding tasks that require both accurate classification and interpretable reasoning. We develop compact VLM architectures with task-specific classification and reasoning capabilities, combining efficient multimodal representations with specialized post-training strategies and reinforecment leanring (RL). For example we developed a compact VLM achieved a 15 to 21 percentage-point reduction in false-positive rate and a 6 percentage-point improvement in precision, while delivering a higher F1 score than a larger model with <25% of its parameters.

API Demo

Click a slide to enlarge.

Lightweight Adaptive Anomaly Detection

Industrial defect detection demands high accuracy with minimal computational overhead. We developed a fast training-free anomaly detection algorithm combining pattern matching, statistical and image-adaptive fusion as a lightweight alternative to deep neural networks. On ceramic debris detection, our method achieved 95.2% F1, compared with 96.3% F1 for ResNet-50, while achieving a 1-percentage-point lower false-positive rate (FPR) and 2× the throughput of the CNN baseline.

Click a slide to enlarge.

Automated Model Evaluation & Checkpoint Selection

Selecting reliable model checkpoints from extensive post-training experiments is costly and difficult when evaluation depends on inconsistent or expensive manual judgments. We develop an automated evaluation framework combining pointwise scoring → listwise ranking → pairwise comparison to assess model quality and identify promising checkpoints. This progressive evaluation strategy supports systematic, repeatable checkpoint selection while reducing the need for exhaustive manual comparisons.

Click a slide to enlarge.

Newton-Based Optimization

Hyperparameter optimization and post-training can require many expensive evaluations, slowing model development and increasing computational costs. We developed a Newton-inspired numerical optimization method that uses local objective information to guide efficient parameter updates and search. In an XGBoost experiment, the approach required 8 optimization iterations versus 320 grid-search evaluations to achieve competitive performance. In VLM post-training, the method improved recall by 1.6 percentage points and precision by 0.8 percentage points in just 6 iterations.

Click a slide to enlarge.